
I am text block. Click edit button to change this text. Lorem ipsum dolor sit amet, consectetur adipiscing elit. Ut elit tellus, luctus nec ullamcorper mattis, pulvinar dapibus leo.
-24%



TSOP 1738 IR Receiver
Original price was: ₹35.00.₹20.00Current price is: ₹20.00. inc. GST

Arduino Nano V3.0
Original price was: ₹1,000.00.₹800.00Current price is: ₹800.00. inc. GST
28BYJ-48 5V Stepper motor
Original price was: ₹210.00.₹160.00Current price is: ₹160.00. inc. GST
- High-quality stepper motor
- Voltage: DC 5V
- Diameter: 25mm
- Step Angle: 5.625 x 1/64
- Reduction Ratio: 1/64
- Rated voltage : 5VDC
- Number of Phase : 4
- Speed Variation Ratio : 1/64
- Stride Angle : 5.625° /64
- Frequency : 100Hz
- DC resistance : 50Ω±7%(25℃)
- Idle In-traction Frequency : > 600Hz
- Idle Out-traction Frequency : > 1000Hz
- In-traction Torque >34.3mN.m(120Hz)
- Self-positioning Torque >34.3mN.m
- Friction torque : 600-1200 gf.cm
- Pull in torque : 300 gf.cm
- Insulated resistance >10MΩ(500V)
- Insulated electricity power :600VAC/1mA/1s
- Insulation grade :A
- Rise in Temperature <40K(120Hz
- Noise <35dB(120Hz,No load,10cm)
Description
28BYJ-48 widely used stepper motor because of its compact size, 5V power supply provided by any controller, and high level of control. It offers a stride angle of 5.625°/64, making 64 steps to complete one rotation (as every step covers 5.625). This stepper motor consists of 4 coils in the unipolar arrangement and each coil is rated for a +5V power supply and hence controlled easily controlled by any microcontroller.
Among the four coils in the motor, one end of all the coil tied to +5V (Red) and the other ends (Orange, Pink, Yellow, and Blue) taken out like wires. The Red wire is connected to a constant +5V supply and this +5V is connected across the coil. This +5V energizes the coil only if the other end of the coil is grounded.
8BYJ-48 is a uni-polar 5V stepper motor that inputs electrical signals and rotates by converting these input signals into mechanical rotation. It offers a reduction gear of 1/64 set and therefore moves in precise 512 steps per revolution. These motors feature low noise, positional control easily without needing extra circuitry and components. Because this provides positional control, this stepper motor is widely used in the tracking of objects.
As this stepper motor consumes a high current, a driver IC is required along with a microcontroller or Arduino. The ULN2003 breakout board is highly recommended as it has high current and voltage than a single transistor and therefore drives a stepper motor easily by enabling a microcontroller. Although it consumes +5V, it can not give high torque, for high torque prefer NEMA17 stepper motor is preferred.
Application
- DIY robotics projects
- CNC machines and 3D printers
- Machines that need precise control
- Motor and security camera
- DVD players
Reviews (0)
Shipping & Delivery

Related products

3.17mm RC Aluminum Bullet Propeller Adapter Holder
- Bore Diameter: 3.7mm (expandable up to 4.1mm).
- Material: Aluminium.
- Colour: Silver.
- Ease of interfacing.
- Rust-free and stain-free aluminum metal construction.
- Used to capture propeller with BLDC motor in quad-copter/multi-rotor/drone.
- High-quality aluminum material.
- Suitable for brushless motors and speed controllers.
- Delicate workmanship.
- High-Quality RC 3.17mm Prop Adaptor For Motor Propeller Plane, Multicopter, Quadcopter
- Dimension: 2.5mm Long x 12mm Diameter
- weight: 4g

Minebea 16PU-M202 Bipolar Stepper Motor
- Step angle 3.75 degree
- Phase current: 0.6 ampere
- Step Angle: 3.75 Degree +/- 5%
- Drive Sequence: Bipolar
- Rated Current per Winding: 0.6 A
- Winding Resistance: 5E5
- Holding Torque Nm (Kg-cm): 0.064 (0.65)
- Rotor Inertia (Kg-cm2): 0.015
- Rated Voltage: Max 40V DC, 12V Typical
- Flange Size: 56.5 mm
- Shaft (with coupling spur gear): 5mm
- Connecting Wire Length: 30 cm
- Holding Torque: 0.074 nm

NEMA 17 5.5 kgcm
- Step Angle : 1.8°
- Holding Torque : 5.5 KgCm
- Operating Voltage : 12 - 16 volts
- Supply Current (A) :1.5 Ampere
- Number of Leads : 6
- Inductance : 5.5 mH
- Resistance : 2.8 Ohms
- Weight (gm) : 363
- Detent Torque (kg-cm) : 2.6
- Frame Size (mm) : 42 x 42
- Inductance Accuracy : ±20%
- Resistance Accuracy : ±10%
- Step Angle Accuracy : ±5%
- Shaft Diameter (mm) : 5
- Shaft Length (mm) : 22
- Input pulse decides the rotation angle of the motor.
- High accuracy of around 3 to 5% a step.
- Provides good starting, stopping and reversing.
- Control of this motor is less costly because of exclusion of complex control circuitry.
- The speed is proportional to the frequency of the input pulses.

NEMA 23 10.1 kg-cm
- Operating Voltage : 2.3 Volts
- Step Angle : 1.8°
- Holding Torque : 10.1 kg-cm
- Supply Current (A) : 2.8 Ampere/Phase
- Number of Leads : 4
- Inductance : 2.2 mH/Phase
- Resistance : 0.83 Ohm
- Rotor Inertia : 275 gm-cm2
- Weight (gm) : 650
- Detent Torque (kg-cm) : 0.36
- Frame Size (mm) : 57 x 57
- Inductance Accuracy : ±20%
- Resistance Accuracy : ±10%
- Shaft Diameter (mm) : 6.35
- Shaft Length (mm) : 20.6
- Step Angle Accuracy : ±5%
- Comparably more powerful than NEMA17 motors.
- The input pulse decides the rotation angle of the motor.
- High accuracy of around 3 to 5% a step.
- It provides good starting, stopping, and reversing.
- Control of this motor is less costly because of the exclusion of complex control circuitry.
- The speed is proportional to the frequency of the input pulses.

Stepper Motor Nema 23 kg 7.2 kg Dual shaft
- Rated Voltage: 6.6 V
- Current/ phase: 1A
- Resistance/ phase: 6.6ohms
- Inductance/ phase: 8.2 mH
- Holding Torque: 7.2 kg-cm
- of Leads - 6
- Rotor Inertia - 275
- Weight: 0.65kg
- Detent Torque: 0.36 kg-cm
- Step Angle - 1.8°
- Step Angle Accuracy - ±5% (full step, no load)
- Resistance Accuracy - ±10%
- Inductance Accuracy - ±20%
- Frame Size (mm) - 57x57
- Shaft Length (mm) - 20.6
- Shaft Diameter (mm) - 6.35
- Comparably more powerful than NEMA17 motors.
- Input pulse decides the rotation angle of the motor.
- High accuracy of around 3 to 5% a step.
- Provides good starting, stopping and reversing.
- Control of this motor is less costly because of exclusion of complex control circuitry.
- The speed is proportional to the frequency of the input pulses.

Stepper Motor NEMA 34 122 kg-cm Hybrid Bipolar
- Rated Voltage:4.08V
- Phase: 2
- Current/ phase: 4A
- Holding Torque: 122 kg-cm
- Number of Leads: 4
- Step Angle: 1.8°
- Step Angle Accuracy: ±5% (full step, no load)
- Resistance Accuracy: ±10%
- Inductance Accuracy: ±20%
- Frame Size: 85x85mm
- Shaft Length: 37mm
- Shaft Diameter: 13mm
- Long-lasting life
- Low cost for control achieved
- High torque at startup and low speeds
- Ruggedness
- Simplicity of construction
- Can operate in an open-loop control system
- Low maintenance
- Less likely to stall or slip
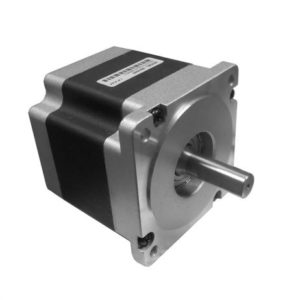
Stepper Motor NEMA 34 68 kg-cm Hybrid Bipolar
- Rated Voltage:4.2V
- Current/ phase: 4A
- Holding Torque: 68 kg-cm
- Number of Leads: 4
- Step Angle: 1.8°
- Step Angle Accuracy: ±5% (full step, no load)
- Resistance Accuracy: ±10%
- Inductance Accuracy: ±20%
- Frame Size: 85x85mm
- Shaft Length: 32mm
- Shaft Diameter: 12mm
- Long-lasting life
- Low cost for control achieved
- High torque at startup and low speeds
- Ruggedness
- Simplicity of construction
- Can operate in an open-loop control system
- Low maintenance
- Less likely to stall or slip

Sunny Sky A2212 980 kv
- Poor man’s Tiger motor
- Brand name: Sunnysky
- KV: 980KV.
- Framework: 12N14P
- Operating Current: 6A ~ 18A
- Peak Current: 14A
- Shaft: 3mm.
- thrust: 880g
- Stator Diameter: 22mm
- Stator Thickness: 12mm
- of Stator Slots: 12
- of Rotor Poles: 14
- Motor Resistance: 123mΩ
- Max Continuous Power: 330W
- Recommended Lipo Batteries: 2-3S
- Recommended Propeller: 9-10
- Recommended Esc between 25A and 30A are
- High-quality bearings for reliable operation.
- Imported silicon steel coils, and high-quality magnets ensuring longer life and better performance.
- Generates less heat during operations.
- Suitable for RC Airplane or Multi rotor helicopter
- Dimension: 27*30mm
- Weight: 50gm
Reviews
There are no reviews yet.