
I am text block. Click edit button to change this text. Lorem ipsum dolor sit amet, consectetur adipiscing elit. Ut elit tellus, luctus nec ullamcorper mattis, pulvinar dapibus leo.
-12%

Solar Panel 9V 200mA
Original price was: ₹525.00.₹475.00Current price is: ₹475.00. inc. GST
Stepper Motor NEMA 34 87 kg-cm Hybrid Bipolar
Original price was: ₹5,550.00.₹5,449.00Current price is: ₹5,449.00. inc. GST
NEMA 17 5.5 kgcm
Original price was: ₹1,079.00.₹950.00Current price is: ₹950.00. inc. GST
- Step Angle : 1.8°
- Holding Torque : 5.5 KgCm
- Operating Voltage : 12 – 16 volts
- Supply Current (A) :1.5 Ampere
- Number of Leads : 6
- Inductance : 5.5 mH
- Resistance : 2.8 Ohms
- Weight (gm) : 363
- Detent Torque (kg-cm) : 2.6
- Frame Size (mm) : 42 x 42
- Inductance Accuracy : ±20%
- Resistance Accuracy : ±10%
- Step Angle Accuracy : ±5%
- Shaft Diameter (mm) : 5
- Shaft Length (mm) : 22
- Input pulse decides the rotation angle of the motor.
- High accuracy of around 3 to 5% a step.
- Provides good starting, stopping and reversing.
- Control of this motor is less costly because of exclusion of complex control circuitry.
- The speed is proportional to the frequency of the input pulses.
Description
Stepper Motor defined as a motor controlled by a series of electromagnetic coils. A series of magnets mounts the centre shaft, and the coils surrounding the shaft are alternately given current or not, generating magnetic fields which repulse or attract the magnets on the shaft, causing the motor to rotate.
The NEMA17 5.5 kg-cm designed as a Single Shaft Stepper Motor providing 5.5 kg-cm of torque at 1.5A current per phase. This stepper motors move in precisely repeatable steps. Hence they are the ideal motors for the machines requiring precise position control. Stepper Motor Drivers used to command to move or hold at one position of motor. The NEMA17 5.5 kg-cm Stepper Motor features excellent response to starting, stopping and reversing pulses from stepper motor driver.
As the NEMA17 5.5 kg-cm is a brushless DC motor, so the life of this motor is completely dependent upon life of the bearings. As this position control achieved by a simple Open Loop control mechanism so doesn’t require complex electronic control circuitry. The motor’s shaft designed for good grip with a pulley, drive gear etc. and especially avoiding stall or slip.This stepper motor provides high accuracy of around 3 to 5% a step. Moreover, the input pulse determines the rotation angle of the motor. In which the frequency of input pulse is directly proportional to the speed. These motors widely used in application which requires low speed with high precision. Such as 3D Printers, CNC Router and Mills, Camera Platforms, XYZ Plotters etc.
Reviews (0)
Shipping & Delivery

Related products

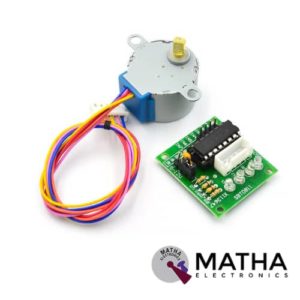
5V Stepper Motor 28BYJ-48 with ULN2003
- Rated voltage: 5V DC
- Reduction Ratio: 64:1
- Step Angle: 5.625° /64
- Frequency: 100Hz
- Self-positioning Torque: >34.3mN.m
- No of phase: 4
- Speed variation ratio: 1/64
- Pull-in torque: 300 gf.cm
- Friction torque: 600-1200 gf.cm
- DC resistance: 50Ω±7% (25°C)
- Insulated resistance: >10MΩ (500V)
- Insulated power: 600VAC/1mA/1s
- Rise in Temperature <40K(120Hz
- Noise <35dB(120Hz,No load,10cm
- Stepper motor with a standard interface, when used directly pluggable.
- Four-phase LED indicator which indicates the status of the stepper motor work.
- Compact size stepper motor perfect for small robotics applications.
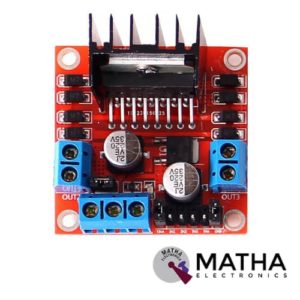

L298N MOTOR DRIVER
- Driver model: L298N 2A
- Driver chip: Double H bridge L298N
- Motor supply voltage: 46V(maximum)
- Motor supply current: 2A(maximum)
- Logic voltage: 5v
- Driver voltage: 5V-35V
- Driver current: 2A
- Logical current: 0-36mA
- Maximum power: 25W
- Current sensor for each motor
- LED indication for power status
- Heat sink for better performance
- Operating temperature: -25 degrees to 135 degrees Celsius
- Can be interfaced with simple manual switches, TTL logic gates, relays, etc.
- Dimension: 55*60*30mm
- Weight: 33gm

NEMA 23 18.9 kg-cm
- Step Angle : 1.8 °
- Holding Torque : 18.9 kg-cm
- Operating Voltage : 3.2 Volts
- Supply Current (A) : 2.8 A/Phase
- No. of Leads : 4
- Inductance: 3.6 mH/Phase
- Resistance : 1.13 O/Phase
- Rotor Inertia : 480 gm-cm2
- Inductance Accuracy : ±20%
- Resistance Accuracy : ±10%
- Shaft Diameter (mm) : 6.35
- Shaft Length (mm) : 20.6
- Cable Length: 30 CM
- Comparably more powerful than NEMA17 motors.
- Input pulse decides the rotation angle of the motor.
- High accuracy of around 3 to 5% a step.
- Provides good starting, stopping and reversing.
- Control of this motor is less costly because of exclusion of complex control circuitry.
- The speed is proportional to the frequency of the input pulses.


Stepper Motor NEMA 34 122 kg-cm Hybrid Bipolar
- Rated Voltage:4.08V
- Phase: 2
- Current/ phase: 4A
- Holding Torque: 122 kg-cm
- Number of Leads: 4
- Step Angle: 1.8°
- Step Angle Accuracy: ±5% (full step, no load)
- Resistance Accuracy: ±10%
- Inductance Accuracy: ±20%
- Frame Size: 85x85mm
- Shaft Length: 37mm
- Shaft Diameter: 13mm
- Long-lasting life
- Low cost for control achieved
- High torque at startup and low speeds
- Ruggedness
- Simplicity of construction
- Can operate in an open-loop control system
- Low maintenance
- Less likely to stall or slip

Stepper Motor NEMA 34 46 kg-cm Hybrid Bipolar
- Rated Voltage:4.2V
- Current/ phase: 4A
- Inductance/ phase: 7.3mH
- Resistance/ phase: 0.87ohms
- Holding Torque: 46 kg-cm
- Number of Leads: 4
- Step Angle: 1.8°
- Step Angle Accuracy: ±5% (full step, no load)
- Resistance Accuracy: ±10%
- Inductance Accuracy: ±20%
- Frame Size: 85x85mm
- Shaft Length: 32mm
- Shaft Diameter: 12mm
- They are high torque stepper motors.
- Input pulse decides the rotation angle of the motor.
- High accuracy of around 3 to 5% a step.
- Provides good starting, stopping and reversing
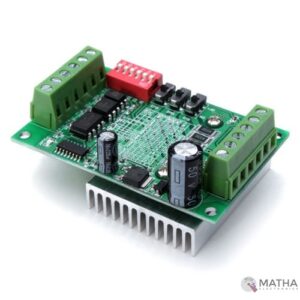
TB6560 Driver Board 3A CNC Router Single 1 Axis Controller Stepper Motor
- Supply voltage up to +32 VDC
- Output current up to 3.0A
- Pulse frequency up to 20 KHz
- Suitable for 2-phase and 4-phase motors
- Over-voltage and short-circuit protection
- 7 output current choices, max 3200 steps/rev
- Automatic idle-current reduction
- Single-chip motor driver for sinusoidal micro-step control of stepping motors
- High output withstands voltage due to the use of BiCD process:
- Forward and reverse rotation
- Selectable phase excitation modes (2, 1-2, 2W1-2, and 4W1-2)
- High output withstand voltage: VDSS = 40 V
- High output current: IOUT = TB6560AHQ: 3.5 A (peak)
- Internal pull-down resistors on inputs: 100 kΩ
- Output monitor pin: MO current (IMO (max) = 1 mA)
- Reset and enable pins
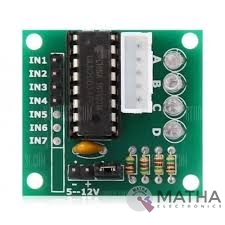
ULN2003 Driver
- Contains 7 high-voltage and high current Darlington pairs
- Each pair is rated for 50V and 500mA
- Input pins can be triggered by +5V
- All seven Output pins can be connected to gather to drive loads up to (7×500mA) ~3.5A.
- Can be directly controlled by logic devices like Digital Gates PIC etc
- Available in 16-pin DIP, TSSOP, SOIC packages
- Dimensions: 32 x 18 x 11mm (LxWxH)
- Weight: 3 gm
Reviews
There are no reviews yet.