
I am text block. Click edit button to change this text. Lorem ipsum dolor sit amet, consectetur adipiscing elit. Ut elit tellus, luctus nec ullamcorper mattis, pulvinar dapibus leo.
-14%Sold out


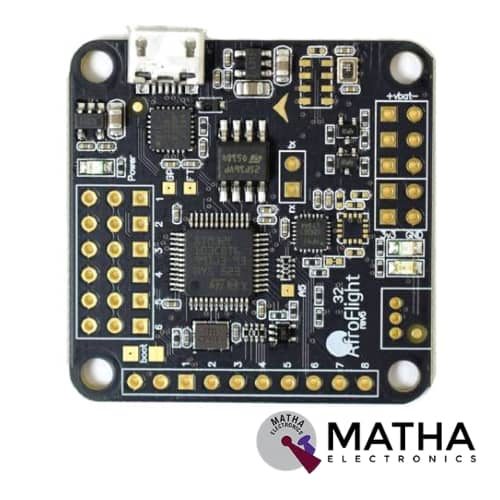
AfroFlight Naze32 Rev6 Flight Controller Board
Original price was: ₹1,799.00.₹1,749.00Current price is: ₹1,749.00. inc. GST
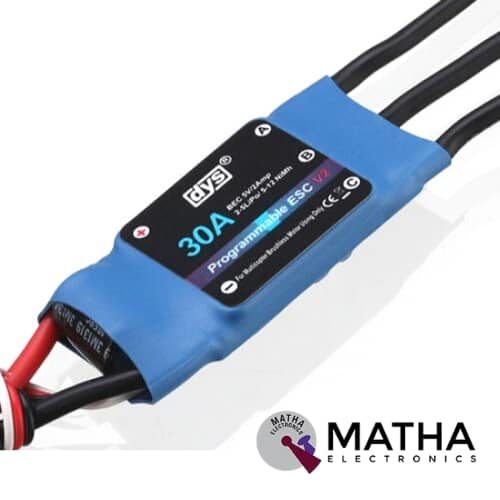
30AMPS ESC DYS
Original price was: ₹1,999.00.₹1,450.00Current price is: ₹1,450.00. inc. GST
Ardupilot Mega APM 2.8 Flight Controller
Original price was: ₹3,500.00.₹2,999.00Current price is: ₹2,999.00. inc. GST
- Model: APM 2.8
- Input Voltage (V): 12-16 V.
- Processor: ATMEGA2560 and ATMEGA32U-2
- Micro SD card slot: No.
- Arduino Compatible
- MPU6000 : 3-Axis MEMS Gyroscope + accelerometer
- High-performance Barometer upgraded to MS5611-01BA03, from Measurement Specialties.
- Support hundreds of 3D waypoints
- Full mission scripting with point-and-click desktop utilities
- Two-way telemetry and in-flight command using the powerful MAVLink protocol
- Powerful Ground Control Software
- Supports full “hardware-in-the-loop” simulation with Xplane and Flight Gear
- On-board 4 Megabyte Data flash chip for automatic data logging.
- Optional off-board GPS, an uBlox LEA-6H module with Compass.
- Dimensions: 70 x 45 x 15mm
- Weight: 70gm
Out of stock
Description
A Flight controller is defined as the brain of the aircraft. It includes a circuit board with a wide range of sensors that detect the movement of the drone, and user commands. As a result, controls the speed of the motors, and makes the craft move as per the data instructed. APM 2.8 Multicopter Flight Controller is an upgraded version of 2.5, 2.6; explicitly designed for FPV RC Drone with a Built-in Compass. The sensors present are exactly the same as the APM 2.6 flight controller. However, the module has the option to use the built-in compass, an external compass connected via a jumper.
The APM 2.8 Multicopter Flight Controller is completely an open-source autopilot system that can control Planes, Copters, and Rovers. These are professional quality IMU autopilot based on the Arduino Mega platform. It allows the user to turn any fixed, rotary-wing, in addition, it is capable of turning the multirotor vehicle into a fully autonomous vehicle. Moreover, it performs programmed GPS missions with waypoints.
The APM 2.8 Multicopter Flight Controller is available with top or side connectors. This board model is designed for vehicles especially in multi-copters and rovers where the compass should be placed as far from power and motor source, to avoid magnetic interference. Basically, on a fixed-wing aircraft, it’s quite easier to mount APM far away from the motors and ESCs to avoid magnetic interference. This APM 2.8 Multicopter Flight Controller is designed to be used with the 3DR uBlox GPS along with Compass. This autopilot features autonomous stabilization, way-point based navigation, and two-way telemetry with Xbee wireless modules. It can Support up to 8 RC channels with 4 serial ports. ArduPilot Mega consists of the main processor board and the IMU shield which fits above or below the processor board.
Reviews (0)
Shipping & Delivery

Related products


8045(8X4.5) Propeller
- Length: 8″
- Pitch: 4.5″
- Weight: 36.5g
- Shaft Diameter: 6mm
- Total Length: 177mm
- Material: ABS
- Durable plastic construction provides both lightness and rigidity.
- 1245(12X4.5) Carbon Fiber Black comes with an Epoxy resin cover.
- Very strong and lightweight.
- Includes set of plastic reducers (3, 3.17, 4, 4.70, 5, 6, 6.25 mm).
- Quick to release, quick to attach
- New design propellers, with greater aerodynamic efficiency, good lifting capacity.
- Dimensions: 30 x 6 x 4 cm
- Weight: 25gm

Anti-Vibration Shock Absorber for APM/KK/MWC/PixHawk
- Colour: Black
- Material: Glass Fibre
- Upper Frame size:90x60x2mm
- Lower Frame Size: 100x70x2mm
- Shock absorber Height: 10×12mm
- Light Weight.
- Vibration Resistant with included Shock absorbers.
- Shock Absorber material: Synthetic Rubber.
- Universal Fiber Mount Shock Absorber Plate for flight controllers
- Compact design
- Super lightweight
- Mounting holes on the bottom makes it easy to install
- Suit for different open-source flight controller, like APM 2.5/2.6/2.8, KK, MWC, and Pixhawk 2.4
- Weight: 2gm
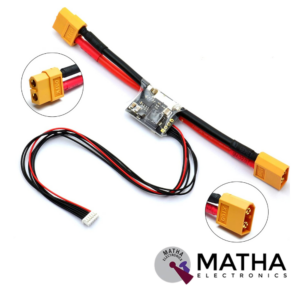
APM/Pixhawk Power Module V6.0 Output BEC 3A XT60 Plug 28V 90A
- Input Voltage Range: 6-28V DC
- Output voltage: 5.3V ± 0.1V
- Maximum output current: 3A
- Maximum current: 90A
- Maximum voltage: 30V
- Supports from 2 cell to 6 cell battery.
- 6P cable can be directly connected to APM/Pixhawk flight control
- Additional 4P rows of pin-free to wire/PIN to connect to another flight control
- Voltage and current measurement configured for 5V ADC.
- Switching regulator outputs 5.3V and 3A max.
- Dimensions: 25mm x 21mm x 9mm
- Weight: 17gm
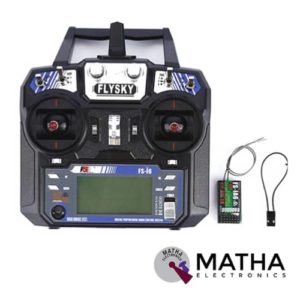
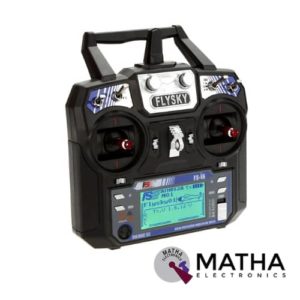
Flysky FS-i6 6 Channel
- Bandwidth (kHz): 500.
- RF Range (GHz): 2.40 ~ 2.48.
- No. of channels: 6.
- Remote controller weight (gm): 400.
- Power: 6V (1.5V AA*4).
- Antenna Length: 26mm * 2 (dual antenna).
- Transmitting Power: ≤ 20dBm.
- RF Receiver Sensitivity: -105dbm.
- Entry-level 6 channel 2.4GHz radio with telemetry capability.
- Easy to use Programming & Navigation Buttons.
- Supports Heli/Standard Wing/Elevon/V-Tail.
- 20 Model Memory.
- 8 Character Model Name.
- Trainer and charging ports.
- The backlight LCD screen displays real-time transmitter and receiver voltage.
- 4 Stick Mode Selectable.
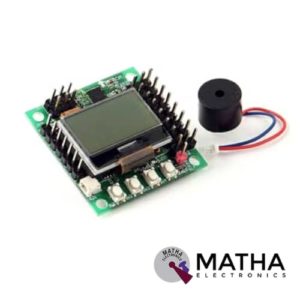
KK-Mini FLIGHT CONTROLLER
- IC: Atmega644 PA
- Gyro/Accelerometer: Auto-level: Yes
- Input Voltage: 4.8-6.0V
- AVR interface: standard 6 pins.
- The signal from Receiver: 1520us (5 channels)
- Signal to ESC: 1520us
- LCD size: 24*18mm
- Mini buttons size: Four 3.3*4.2mm
- Mounting holes: 30.5x30.5mm
- Voltage sensor: One red positive pin header for.
- Input rail: Single row 2.54mm pitch pin header for input signal
- Firmware Version: 1.6
- Dimension: 36x36x11.5mm


Mini OSD W/ KV Team MOD For Racing F3 Naze32 Flight Controller RC Drone
- NO DC/DC converter, hence less heating
- FTDI cable compatible pinout
- Standard 6-pin ISP header
- Two LED indicators
- ATmega328P with Arduino bootloader
- MAX7456 monochrome on-screen display
- Pad for an Analog or Digital PWM RSSI signal
- Pad for the connection of a Current Sensor
- ATmega328P with Arduino bootloader
- Standalone, or with APM / Flip / Flip32+ flight controllers
- These modifications allow direct connection of two batteries (up to 4S)
- This hardware takes the hardware mods for this firmware and builds them into an RTF solution.
- This Board can be used just as a normal OSD for APM or it can be used with MWC KV Team Mod.
- Two independent power sections with an LED indicator on each.
- Solder jumpers for combining the power sections
- Solder jumper for PAL video option
- +5V 500mA regulator for up to +12V supply input
- Exposed test points for HSYNC and LOS ATmega328P with Arduino bootloader.
- Dimension: 16 x 16mm


QAV250 Quad-copter Frame
- Item name: QAV250 Frame Kit
- Arm plate thickness: 3mm
- Main material: 3k carbon fibre
- Wheelbase: 250mm
- The arm equips dampers for a safe landing.
- The arm has multiple motor mounting holes.
- Equips vibration-free mounting bracket for FPV camera.
- Recommend Propeller: 5 inch
- Recommend Motor: 1806 2204 2206
- Recommend ESC: 8A-12A
- Recommend Battery: 1300Mah-2200Mah


Ublox NEO-M8N GPS Module with Compass for APM with extra connector for Pixhawk
- Ready to Connect to All APM FC with 5-pin connector Attached
- Receiver type 72-channel M8 engine
- Galileo-ready E1B/C (NEO-M8N)
- update rate1 Single GNSS: up to 18 HZ
- Position accuracy 22.0 m CEP
- Acquisition2 Cold starts: 26 s
- Sensitivity2 Tracking & Nav: –167 dBm
- On-board Compass
- Dimensions: Outer diameter 54mm
- GPS/QZSS L1 C/A, GLONASS L10F, BeiDou B1.
- SBAS L1 C/A: WAAS, EGNOS, MSAS.
- Assistance AssistNow GNSS Online.
- Assist Now GNSS Offline (up to 35 days)3.
- Assist Now Autonomous (up to 6 days).
- OMA SUPL & 3GPP compliant
- Oscillator TCXO (NEO-M8N/Q).
- Crystal (NEO-M8M).
- RTC crystal Built-In.
- Noise figure On-chip LNA (NEO-M8M). Extra LNA for.
- Lowest noise figure (NEO-M8N/Q).
- Anti-jamming Active CW detection and removal.
- Extra onboard SAW bandpass filter (NEO-M8N/Q).
- Memory ROM (NEO-M8M/Q) or Flash (NEO-M8N).
- Supported antennas Active and passive.
- Odometer Travelled distance.
- Data-logger For position, velocity, and time (NEO-M8N).
- Weight 33gm
Reviews
There are no reviews yet.