
I am text block. Click edit button to change this text. Lorem ipsum dolor sit amet, consectetur adipiscing elit. Ut elit tellus, luctus nec ullamcorper mattis, pulvinar dapibus leo.
-12%

Solar Panel 9V 200mA
Original price was: ₹525.00.₹475.00Current price is: ₹475.00. inc. GST
Stepper Motor NEMA 34 87 kg-cm Hybrid Bipolar
Original price was: ₹5,550.00.₹5,449.00Current price is: ₹5,449.00. inc. GST
NEMA 17 5.5 kgcm
Original price was: ₹1,079.00.₹950.00Current price is: ₹950.00. inc. GST
- Step Angle : 1.8°
- Holding Torque : 5.5 KgCm
- Operating Voltage : 12 – 16 volts
- Supply Current (A) :1.5 Ampere
- Number of Leads : 6
- Inductance : 5.5 mH
- Resistance : 2.8 Ohms
- Weight (gm) : 363
- Detent Torque (kg-cm) : 2.6
- Frame Size (mm) : 42 x 42
- Inductance Accuracy : ±20%
- Resistance Accuracy : ±10%
- Step Angle Accuracy : ±5%
- Shaft Diameter (mm) : 5
- Shaft Length (mm) : 22
- Input pulse decides the rotation angle of the motor.
- High accuracy of around 3 to 5% a step.
- Provides good starting, stopping and reversing.
- Control of this motor is less costly because of exclusion of complex control circuitry.
- The speed is proportional to the frequency of the input pulses.
Description
Stepper Motor defined as a motor controlled by a series of electromagnetic coils. A series of magnets mounts the centre shaft, and the coils surrounding the shaft are alternately given current or not, generating magnetic fields which repulse or attract the magnets on the shaft, causing the motor to rotate.
The NEMA17 5.5 kg-cm designed as a Single Shaft Stepper Motor providing 5.5 kg-cm of torque at 1.5A current per phase. This stepper motors move in precisely repeatable steps. Hence they are the ideal motors for the machines requiring precise position control. Stepper Motor Drivers used to command to move or hold at one position of motor. The NEMA17 5.5 kg-cm Stepper Motor features excellent response to starting, stopping and reversing pulses from stepper motor driver.
As the NEMA17 5.5 kg-cm is a brushless DC motor, so the life of this motor is completely dependent upon life of the bearings. As this position control achieved by a simple Open Loop control mechanism so doesn’t require complex electronic control circuitry. The motor’s shaft designed for good grip with a pulley, drive gear etc. and especially avoiding stall or slip.This stepper motor provides high accuracy of around 3 to 5% a step. Moreover, the input pulse determines the rotation angle of the motor. In which the frequency of input pulse is directly proportional to the speed. These motors widely used in application which requires low speed with high precision. Such as 3D Printers, CNC Router and Mills, Camera Platforms, XYZ Plotters etc.
Reviews (0)
Shipping & Delivery

Related products

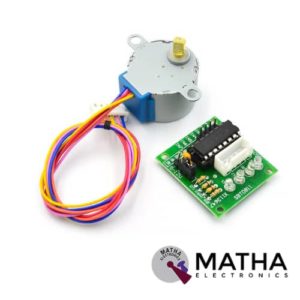
5V Stepper Motor 28BYJ-48 with ULN2003
- Rated voltage: 5V DC
- Reduction Ratio: 64:1
- Step Angle: 5.625° /64
- Frequency: 100Hz
- Self-positioning Torque: >34.3mN.m
- No of phase: 4
- Speed variation ratio: 1/64
- Pull-in torque: 300 gf.cm
- Friction torque: 600-1200 gf.cm
- DC resistance: 50Ω±7% (25°C)
- Insulated resistance: >10MΩ (500V)
- Insulated power: 600VAC/1mA/1s
- Rise in Temperature <40K(120Hz
- Noise <35dB(120Hz,No load,10cm
- Stepper motor with a standard interface, when used directly pluggable.
- Four-phase LED indicator which indicates the status of the stepper motor work.
- Compact size stepper motor perfect for small robotics applications.

Bullet Connector 3.5MM
- Diameter: 3.5mm
- Length:1.5CM & 1.5CM
- Amperage Rating: 60A -180Amps
- Hook up RC Battery to Electronic
- Hook up Brushless motor to electronic speed control
- These have low resistance and gives the best electric flow
- 5mm gold connectors Male
- 5mm gold connectors Female
- Dimension: 2.7*2.1*3inch
- Weight: 67gm


MOTOR SHIELD L293
- 2 connections for 5V ‘hobby’ servos connected to the Arduino’s high-resolution dedicated timer
- 4 H-Bridges: L293D chipset provides 0.6A per bridge (1.2A peak) with thermal shutdown protection, internal kickback protection diodes.
- Can run motors on 4.5VDC to 25VDC.
- Up to 4 bi-directional DC motors with individual 8-bit speed selection (so, about 0.5% resolution)
- Up to 2 stepper motors (unipolar or bipolar) with single coil, double coil, or interleaved stepping.

NEMA 23 10.1 kg-cm
- Operating Voltage : 2.3 Volts
- Step Angle : 1.8°
- Holding Torque : 10.1 kg-cm
- Supply Current (A) : 2.8 Ampere/Phase
- Number of Leads : 4
- Inductance : 2.2 mH/Phase
- Resistance : 0.83 Ohm
- Rotor Inertia : 275 gm-cm2
- Weight (gm) : 650
- Detent Torque (kg-cm) : 0.36
- Frame Size (mm) : 57 x 57
- Inductance Accuracy : ±20%
- Resistance Accuracy : ±10%
- Shaft Diameter (mm) : 6.35
- Shaft Length (mm) : 20.6
- Step Angle Accuracy : ±5%
- Comparably more powerful than NEMA17 motors.
- The input pulse decides the rotation angle of the motor.
- High accuracy of around 3 to 5% a step.
- It provides good starting, stopping, and reversing.
- Control of this motor is less costly because of the exclusion of complex control circuitry.
- The speed is proportional to the frequency of the input pulses.


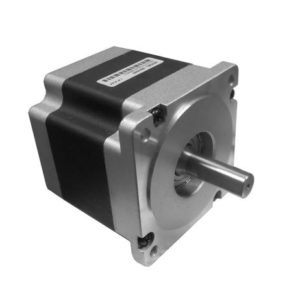
Stepper Motor NEMA 34 87 kg-cm Hybrid Bipolar
- Rated Voltage:4.2V
- Current/ phase: 5A
- Holding Torque: 87 kg-cm
- Number of Leads: 4
- Step Angle: 1.8°
- Step Angle Accuracy: ±5% (full step, no load)
- Resistance Accuracy: ±10%
- Inductance Accuracy: ±20%
- Frame Size: 85x85mm
- Shaft Length: 32mm
- Shaft Diameter: 12mm
- They are high torque stepper motors.
- Input pulse decides the rotation angle of the motor.
- High accuracy of around 3 to 5% a step.
- Provides good starting, stopping and reversing
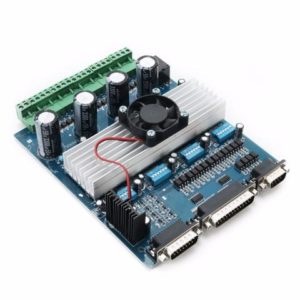
TB6560 4 Axis Cnc Controller 4 Axis Stepper Motor Driver DSP Controlled 3.5A 24V
- Rated maximum output: ± 4.5A, 40V, Peak 5A, low output impedance, source 0.5?,
- the receiving end of 0.4?, low voltage shutdown, thermal parking and circulation.
- circuit protection. After I design, you can set the current output of 0.5A 1A 1.8A 2.5A.
- 3.3A 4A 4.5A to accommodate more and different motor Current.
- The drive is suitable software mach2, mach3, (mach3 have support WIN7 system), KCAM4 like.
Reviews
There are no reviews yet.